Nonlinear Model Predictive Control
Long-horizon optimization, distance-domain formulations, real-time solution methods and constrained marine manoeuvring.
I'm Ferhan Büyükçolak, an autonomous systems engineer and marine robotics researcher focused on vessel dynamics, model predictive control, path planning and real-world validation.
Interactive, browser-based research tools make control concepts easier to inspect and compare.
Explore distance-domain nonlinear model predictive control for marine path following on three routes and three N/M settings. Inspect the reference path, simulated vessel trajectory, MPC prediction, control commands and diagnostics. The browser viewer replays frozen simulation results; it does not run the controller or vessel model.
Open interactive playground ↗Explore curvature-preview marine guidance with an animated vessel, nominal waypoint geometry, cross-track and heading error, curvature commands and rudder response. The browser viewer replays frozen Python simulation results; it does not run the controller or vessel model.
Open interactive playground ↗Watch a compact Panamax model transit the Bosphorus northbound under closed-loop distance-domain NMPC, from route planning to arrival, with the live prediction horizon and measured results. Simulation with zero current; waves are visual only.
Watch the transit ↗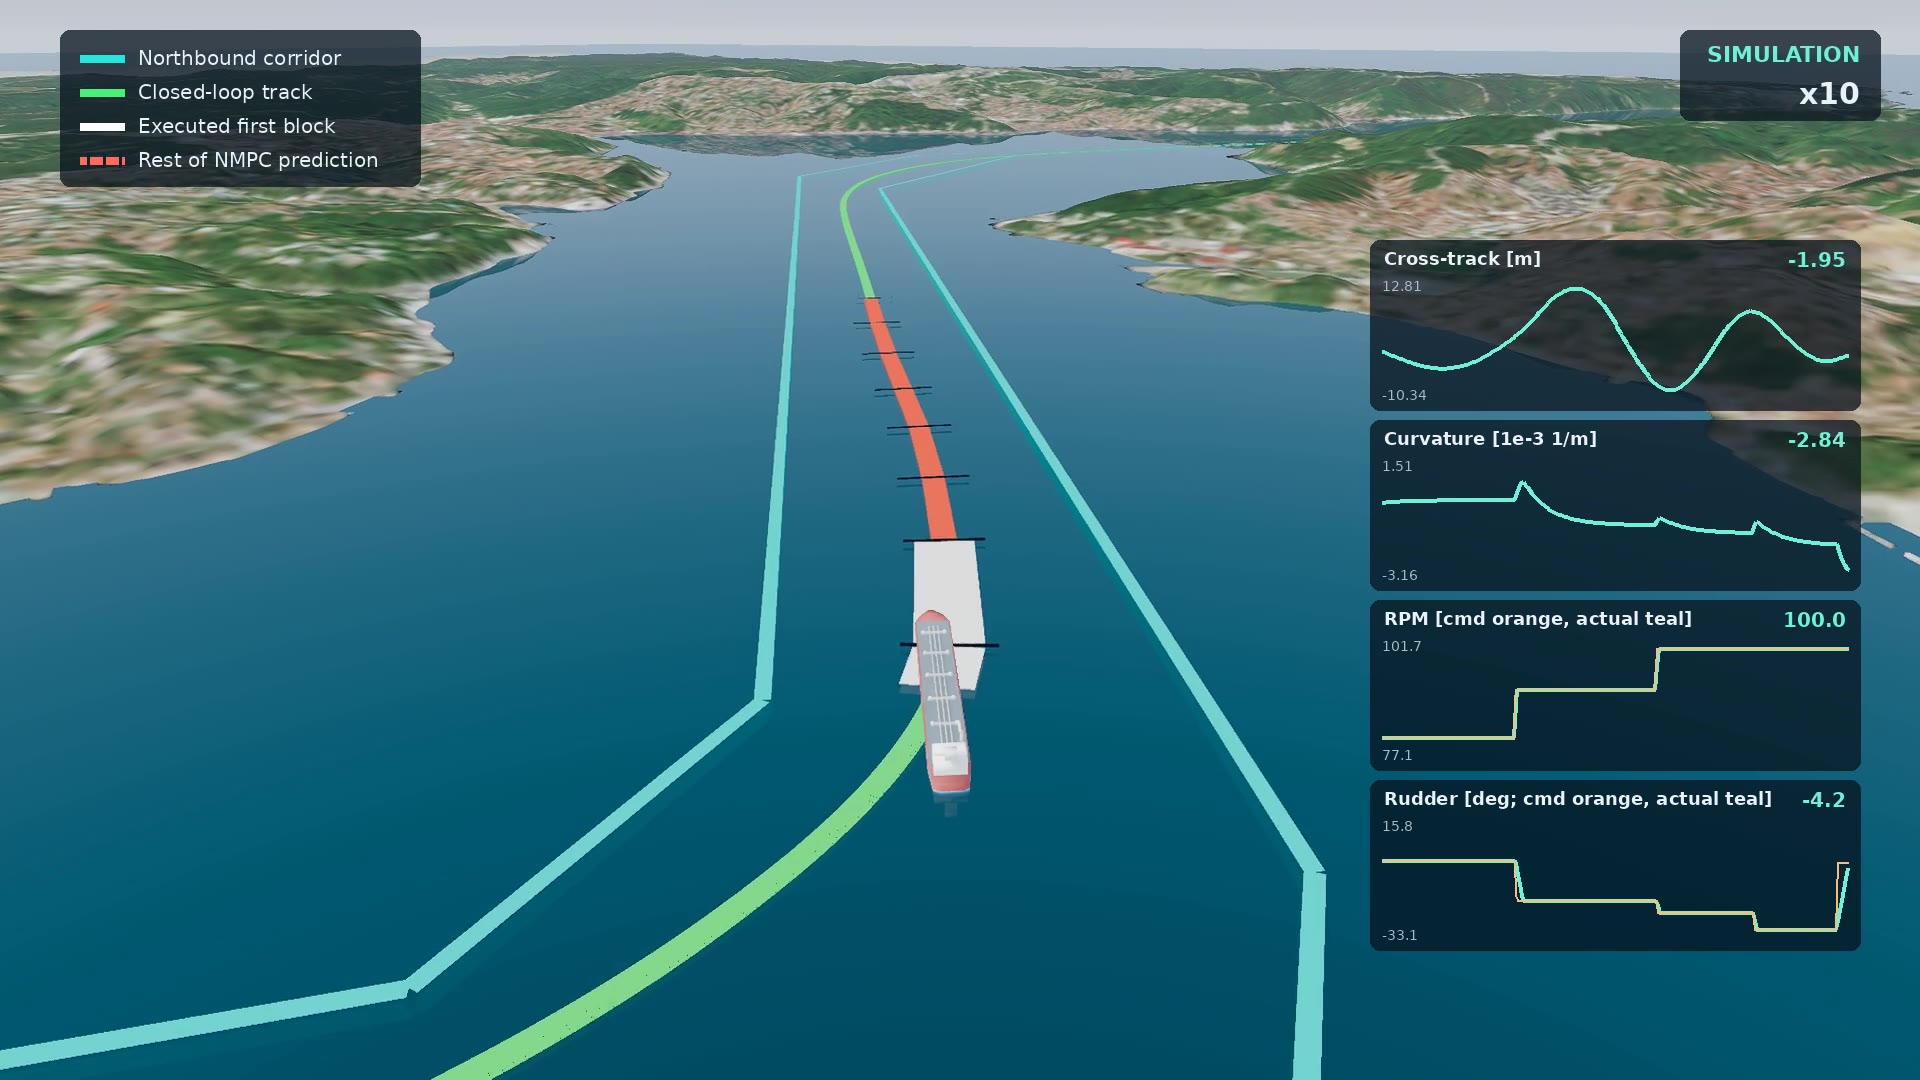
Long-horizon optimization, distance-domain formulations, real-time solution methods and constrained marine manoeuvring.
Curvature-aware routes, tracking and capture behaviour, autonomous navigation and guidance for surface vessels.
System identification, HIL testing, onboard integration and experimental evaluation of autonomous marine systems.
Research on vessel manoeuvring, port decision support, docking feasibility and maritime autonomy.
Autonomous surface vessel control, HIL infrastructure, guidance, integration and sea trials.
USV autonomy, manoeuvring models, nonlinear control, formation testing and sea trials.
Open to research discussions and engineering collaboration in marine autonomy.